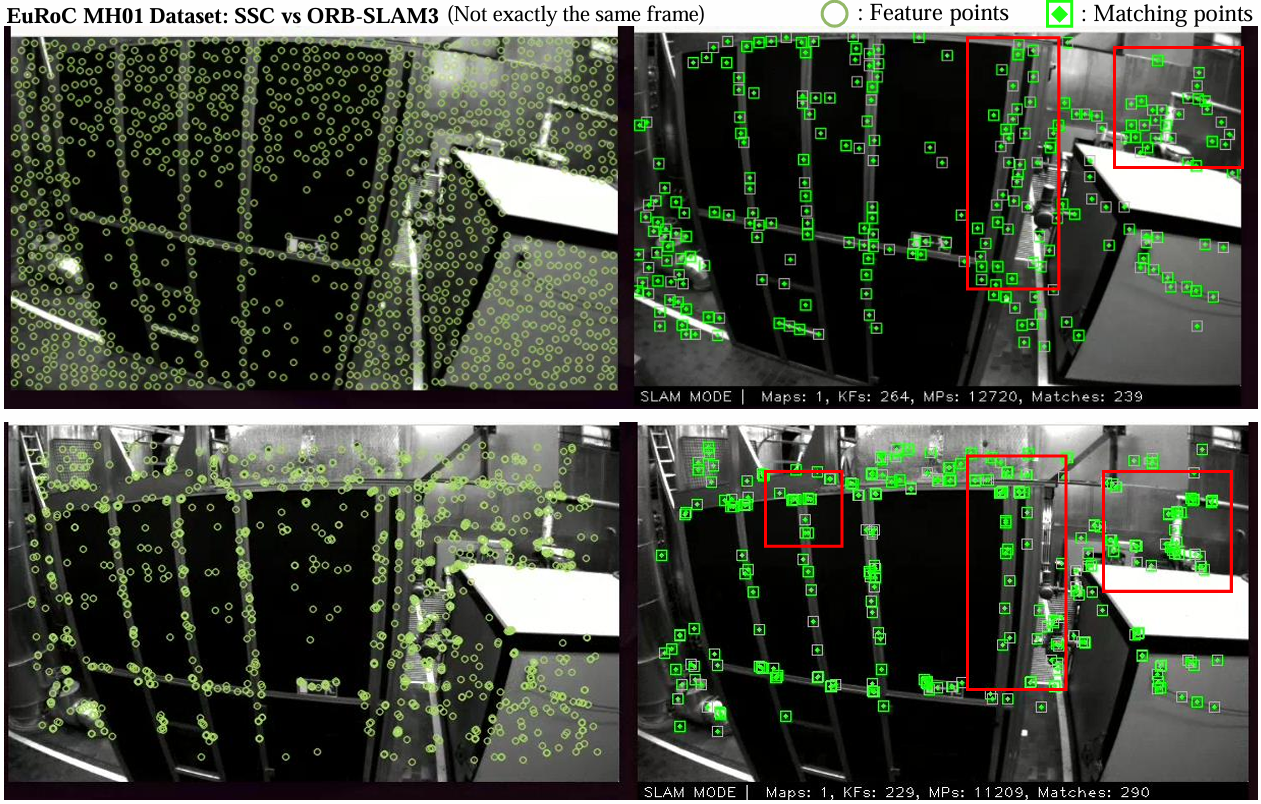
Overview
This project studies spatially balanced ORB feature selection for visual SLAM. It integrates SSC-based adaptive non-maximal suppression into the ORB keypoint selection stage of ORB-SLAM3, with the goal of improving feature coverage and tracking stability.
References
- Bailo, O. et al. (2018). Efficient adaptive non-maximal suppression algorithms for homogeneous spatial keypoint distribution. Pattern Recognition Letters, 106, 53–60.
- Campos, C. et al. (2021). ORB-SLAM3: An accurate open-source library for visual, visual-inertial and multi-map SLAM. IEEE Transactions on Robotics, 37(6), 1874–1890.