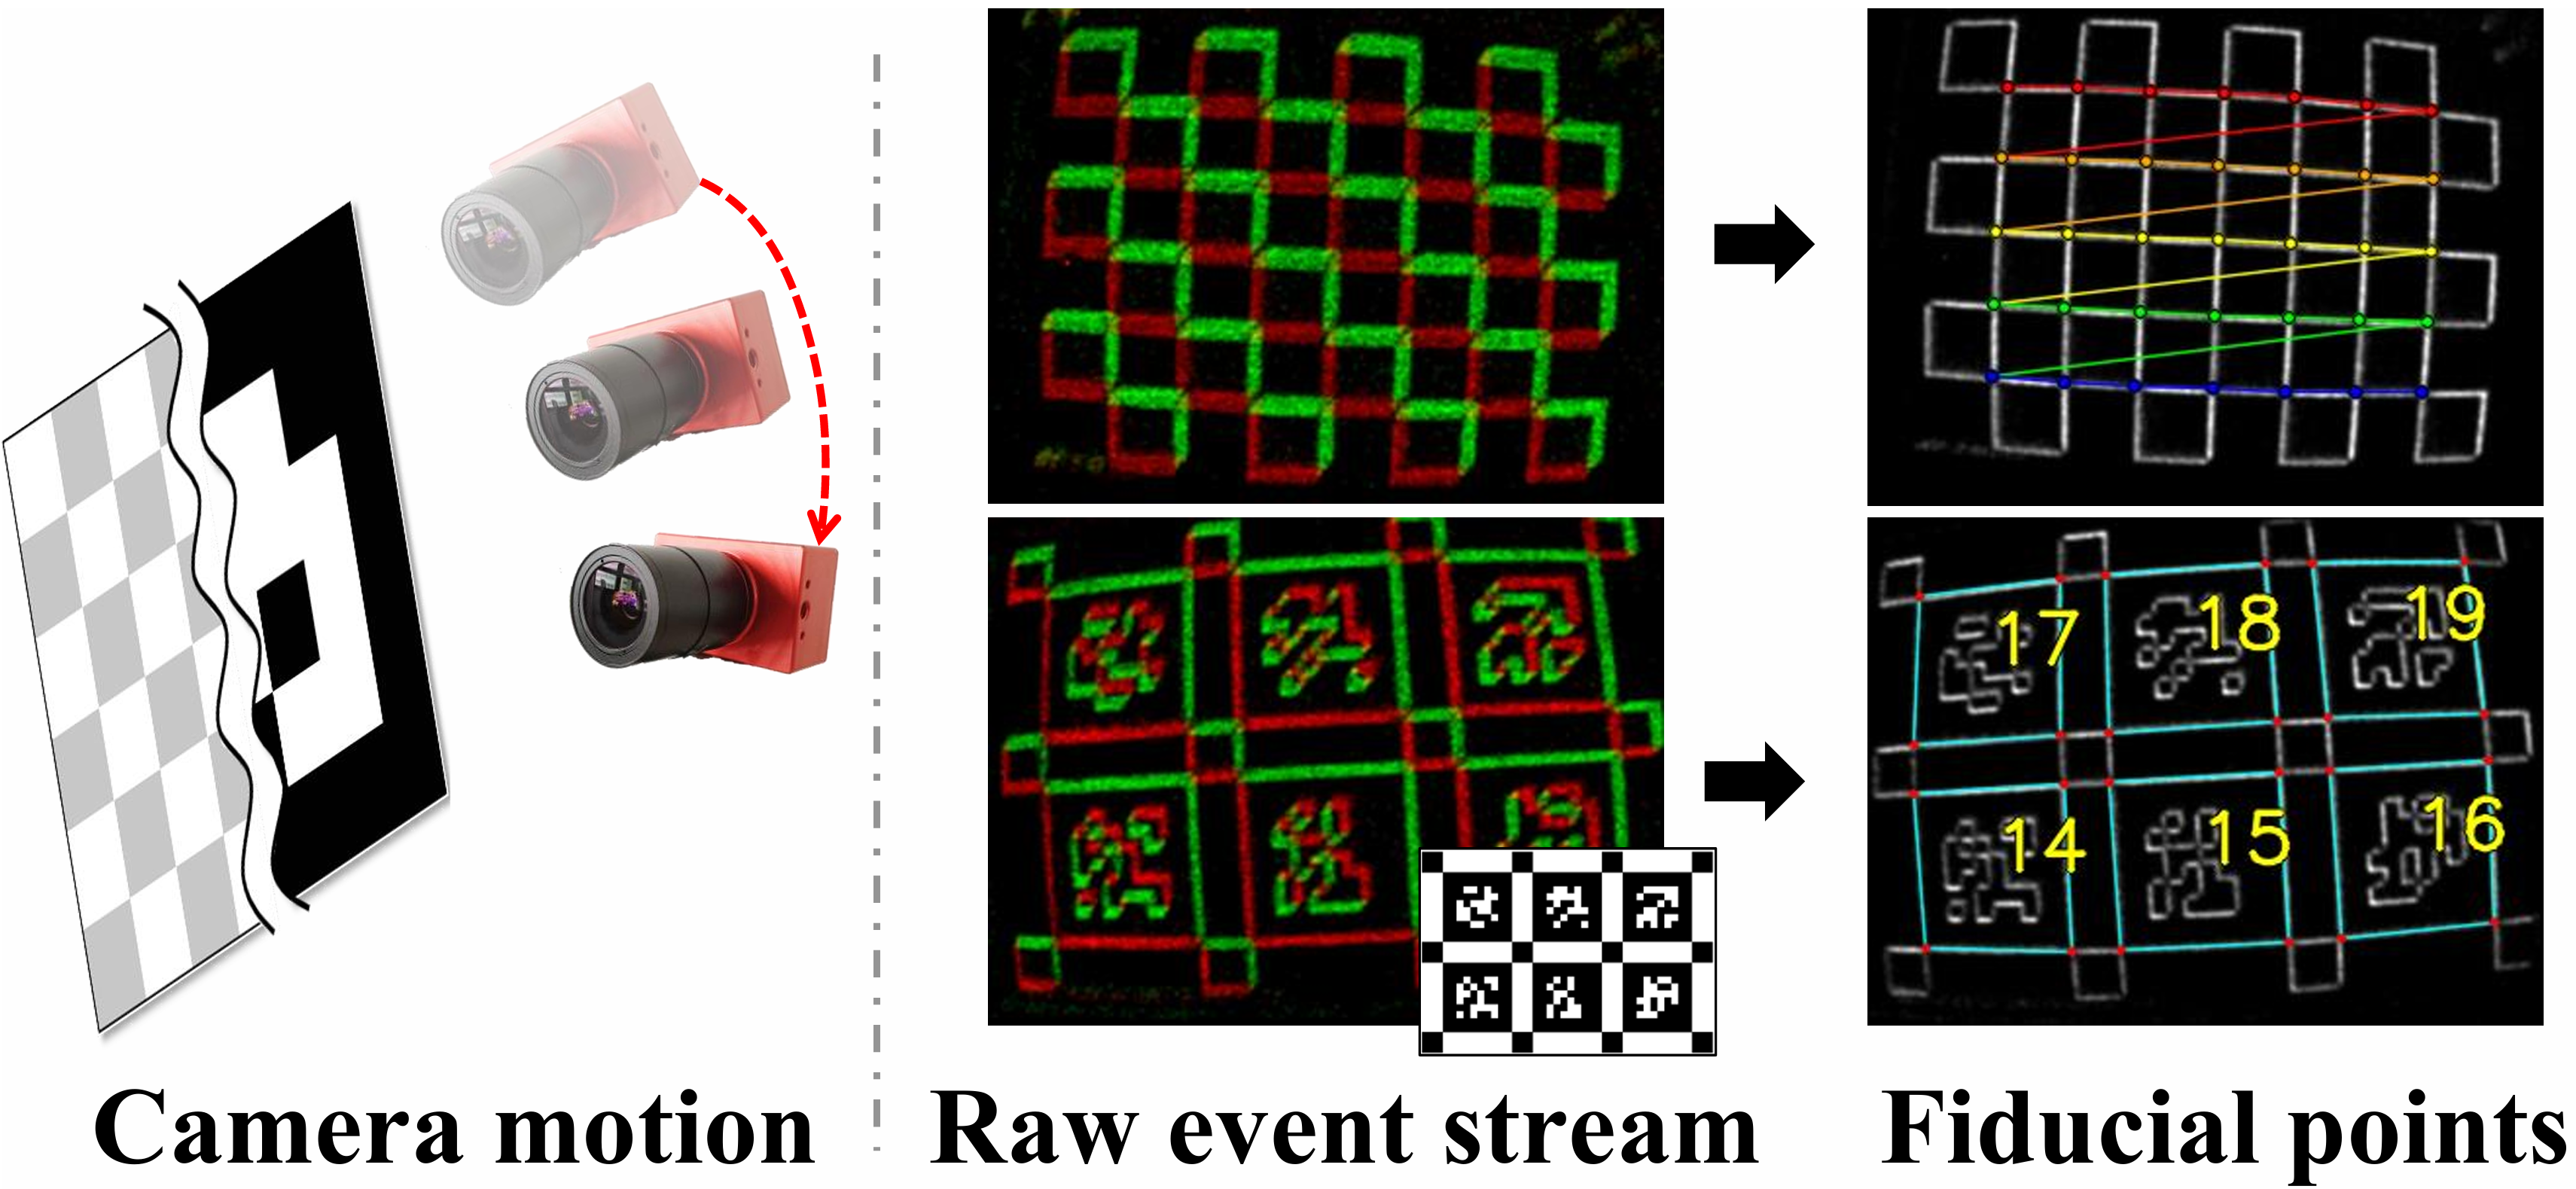
From Corners to Fiducial Tags: Revisiting Checkerboard Calibration for Event Cameras
CVPR HighlightCVPR 2026 · IEEE/CVF Conference on Computer Vision and Pattern Recognition
ROBOTICS RESEARCHER
I work on event-based robot vision, sensor calibration, and geometric perception for robotics.
Ph.D. student at UNIST, working in the 3D Vision & Robotics Lab.
Research
1 Conference Paper
CVPR 2026 · IEEE/CVF Conference on Computer Vision and Pattern Recognition
Systems & prototypes
Recognition
2024
Intelligent Robotics Consortium Creative Capstone Design Competition · National competition
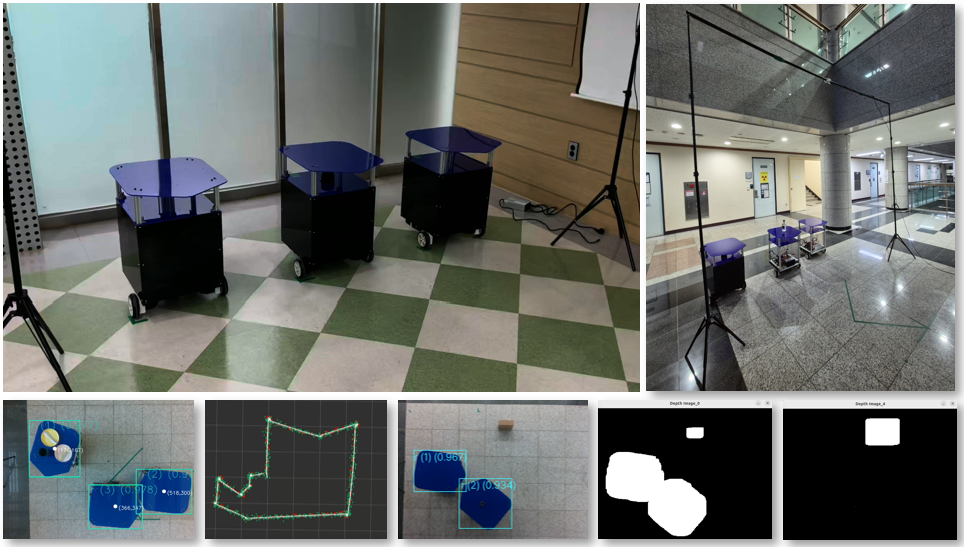
Table Robot System2024
Creative Capstone Design Competition · Hanyang University ERICA, College of Engineering
1st place at the college level; qualified for the national competition.
Table Robot System2024
Capstone Design Fair · Hanyang University ERICA, Department of Robotics
1st place at the department level; qualified for the college competition.
Table Robot System2024
Undergraduate Student Paper Competition · Institute of Control, Robotics, and Systems
Paper2023
Digital Innovation Sharing University Robot Building Competition
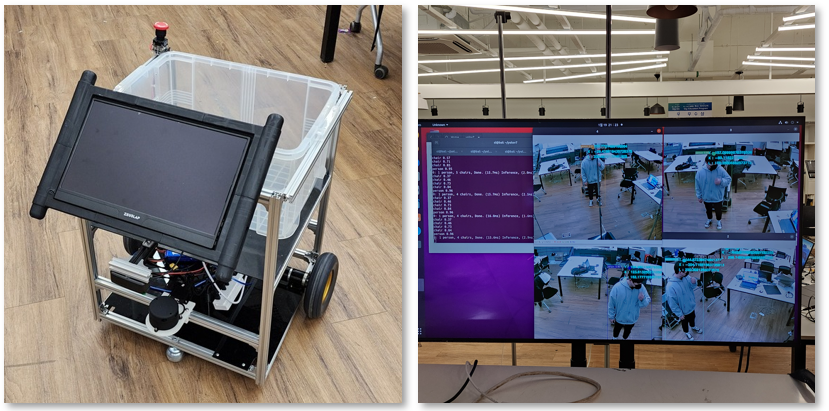
Large Unmanned Store SystemSpring 2024
Hanyang University ERICA
Selected as the sole recipient among all first- through fourth-year students in the Department of Robotics.
Fall 2023
Korea Student Aid Foundation
2022–2023
Hanyang University ERICA
Background
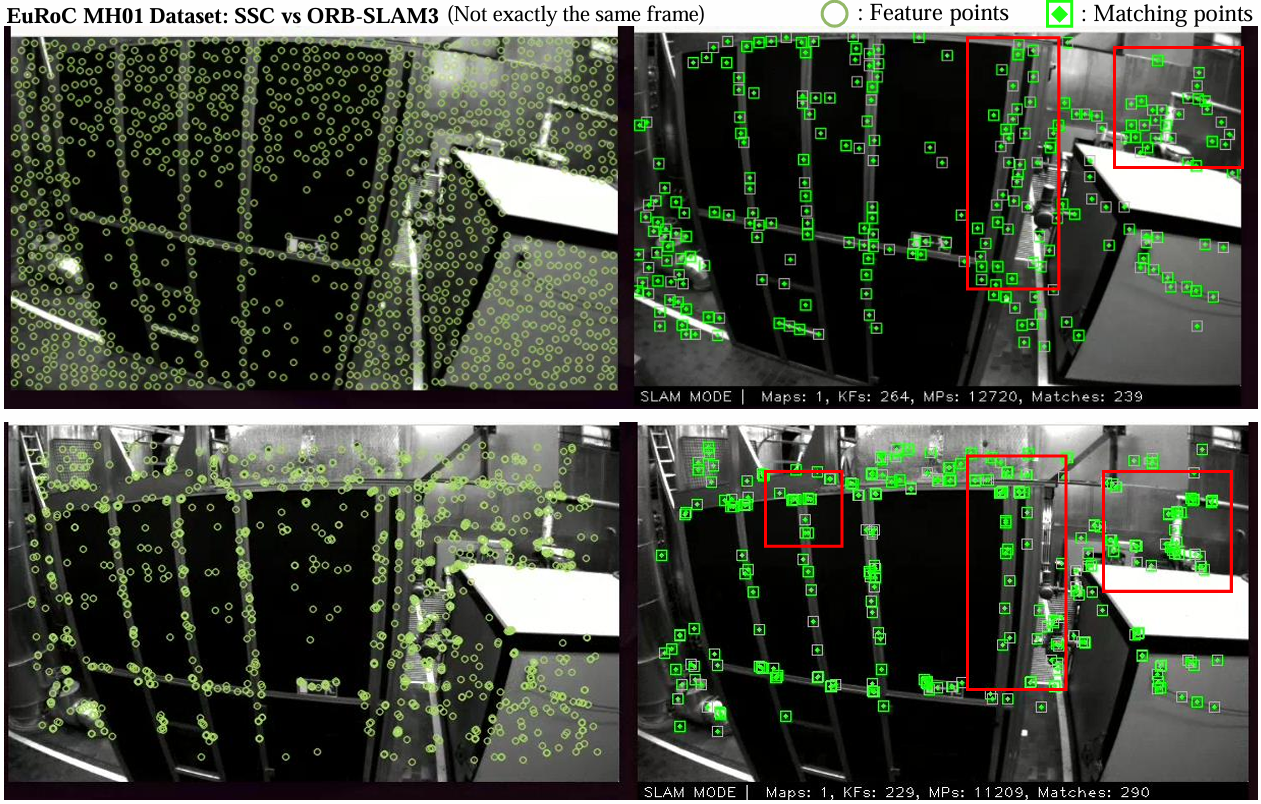
I received my B.S. in Robotics, with a minor in Artificial Intelligence, from Hanyang University ERICA. During my undergraduate studies, I worked on robot localization and perception, which led me to explore visual SLAM and sensor calibration.
Building on this background, I am pursuing a Ph.D. in Artificial Intelligence at UNIST, advised by Prof. Kyungdon Joo in the 3D Vision & Robotics Lab. My current research focuses on event-based vision and sensor calibration, with a broader interest in geometric perception for robotics.
2025.03 – Present
Ulsan National Institute of Science and Technology (UNIST)
Advisor: Kyungdon Joo
2019.03 – 2024.08
Hanyang University ERICA
Minor in Artificial Intelligence · Graduated early with highest honors · Completed two years of mandatory military service
2024.07 – 2025.02
Ulsan National Institute of Science and Technology (UNIST)
Advisor: Kyungdon Joo
Project: Visual SLAM Enhancement